Abel Mendoza

Robotics & Embedded Systems Engineer

Abel Mendoza with computers

Based in Southern California · Open to UAV, robotics, electronics, aerospace, and defense roles.

I like writing code for the web, electronics and embedded systems, and tinkering with robotics.

When I'm not coding I like aggressively cuddling others on the jiu jitsu mat, reading, and educating myself.

Featured Work


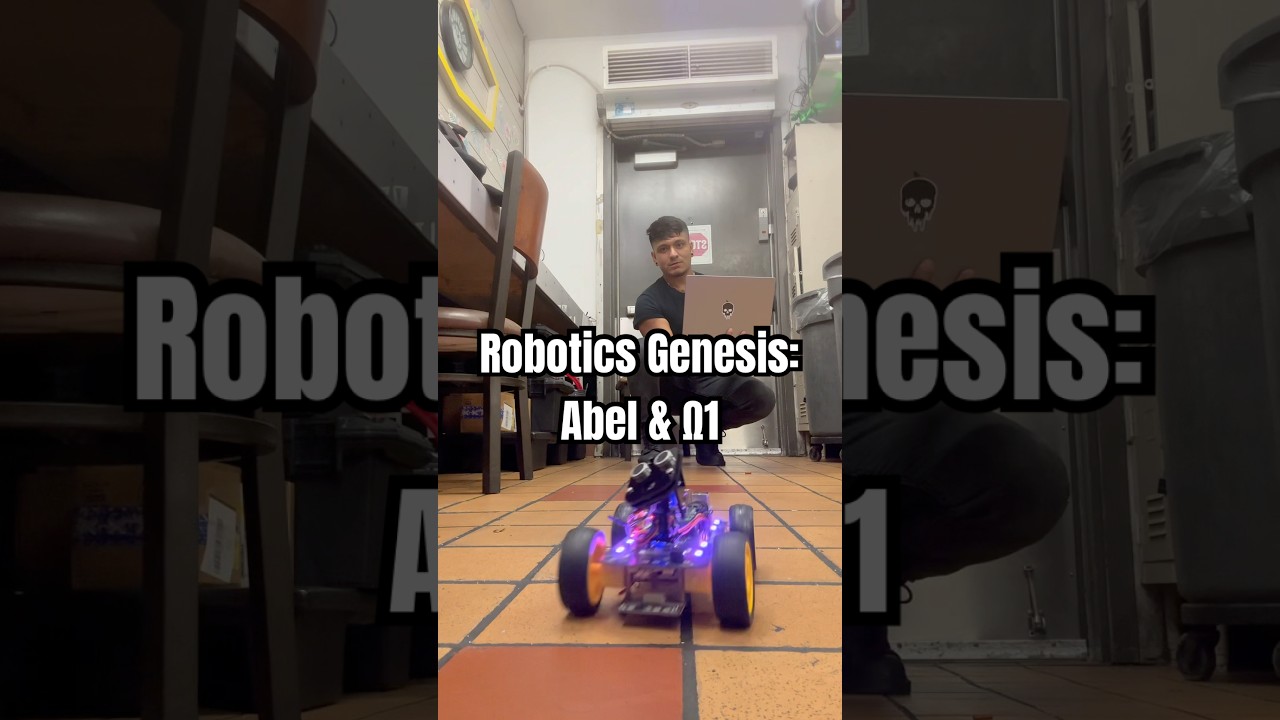
Omega-1 robot project showcase video thumbnail

Project Showcase

In this video, I'm showcasing my Ω1 robot. Check out my YouTube channel for more robotics videos.

Projects

Selected work in robotics, autonomy, and systems engineering.

Omega-1 Autonomous Robotics Platform

Omega-1 — Autonomous Robotics Platform

A fully operational autonomous robot running on Raspberry Pi 4B — drives, navigates, streams live video, and tracks its own position in real time. Controlled from a custom web dashboard with Xbox controller support, live sensor feeds, and a mission control map.

Built as a distributed system across three machines: the Pi handles real-time motor control and sensor fusion, a web UI runs on any laptop with no robot software installed, and an NVIDIA Jetson Orin handles GPU-accelerated object detection — all communicating over a VPN-secured network.

🤖 Autonomous Navigation 📷 Live Video Streaming 📍 Real-Time Localization 📡 Multi-Machine Network
  • Drives autonomously with obstacle avoidance — ultrasonic sensor triggers deceleration, pivot, and heading recovery without stopping abruptly
  • Estimates its own position using a Kalman filter that fuses dead-reckoning (motor commands) with visual landmark corrections (ArUco markers) — no GPS required
  • Streams live camera video to the browser with under 100 ms latency via a custom MJPEG proxy
  • Runs a full software simulation mode: the robot's physics and sensor geometry are modeled so the entire stack can be developed and tested without hardware
  • Detects objects with YOLOv8 on the Jetson Orin and relays results back to the Pi in real time over a compressed image stream (~500 KB/s vs 9 MB/s raw)
  • Solved a hardware bug where the motor driver corrupted servo signals at power-on — traced to a shared PWM clock; fixed with register verification and hard pulse clamping on every write
  • Eliminated ~240 unnecessary HTTP requests/minute from the frontend by introducing circuit breakers, shared polling contexts, and WebSocket health checks
  • Stack: Python · Go · TypeScript · React · Next.js · FastAPI · ROS2 · OpenCV · WebSockets · Docker · TailwindCSS
  • Status: Fully operational — live teleoperation, sensor streaming, localization, and multi-machine communication all running.
PX4 / ROS 2 Autonomy and Verification Platform

PX4 / ROS 2 Autonomy & Verification Platform

Autonomous UAV development and verification platform built with PX4, ROS 2 Humble, Gazebo Harmonic, MAVSDK, MAVLink, Python, and C++. Features autonomous navigation, cooperative multi-UAV missions, fault injection, sensor integration, and requirements-based verification. Includes an interactive 3D flight replay application built with Three.js.

🚁 Autonomous Navigation 🤖 Multi-UAV Coordination 🛡️ Fault Injection & Recovery 🧪 Verification & CI/CD 🌐 Interactive 3D Replay
  • ROS 2 mission state machines, A* path planning, LiDAR-based reactive obstacle avoidance, geofencing, failsafe handling, and resource-aware mission control
  • Cooperative two-UAV missions with task allocation, route reservations, separation monitoring, watchdogs, and automatic task reassignment after confirmed vehicle failure
  • Requirements-based verification: a 26-requirement catalog, independent telemetry analysis, fault injection, regression testing, and PASS/FAIL/SKIP reporting
  • 450 ROS-enabled Python tests, 27 browser tests, and 41 C++ checks, with GitHub Actions CI/CD and reproducible evidence reports
  • Stereo visual odometry, IMU fusion, velocity PID control, ArUco precision landing, and simulated GPS-aiding-loss handling
  • MAVLink v2 communication utilities, vehicle abstraction interfaces, and telemetry pipelines for simulated and hardware-facing integration
  • Two-UAV fault-recovery mission verified across 641 telemetry samples, two task reassignments, and 8.095 m minimum sampled horizontal separation against a 2.5 m requirement
  • Mission-completion defects found and corrected through independent verification, with the failing evidence kept as regression tests
  • Browser-based Three.js flight replay that visualizes recorded missions and fault recovery without a local PX4/Gazebo install
  • Stack: PX4 v1.15+ · ROS 2 Humble · Gazebo Harmonic · Python · C++ · MAVSDK · MAVLink · Micro XRCE-DDS · OpenCV · Three.js · GitHub Actions
Jetson RealSense Perception System project preview

Jetson RealSense Perception

Embedded RGB-D perception toolkit for NVIDIA Jetson Orin Nano and Intel RealSense D455. Supports standalone pyrealsense2 workflows and ROS2 Humble integration, validated on Ubuntu 22.04 / JetPack L4T 36.4.7.

🟦 NVIDIA Jetson Orin Nano 📷 Intel RealSense D455 🛠️ librealsense 2.0 (RSUSB) 🐢 ROS2 Humble
  • Standalone scripts: capture, camera info probe, obstacle detection, point clouds, IMU, occupancy mapping
  • ROS2 wrapper validation: realsense2_camera launch, topic sanity, camera_info intrinsics, topic publishers
  • Documentation + onboarding: hardware setup, software setup, ROS2 setup, troubleshooting, validation checklist
  • Full validation: rs-enumerate-devices and check_realsense.py; depth/color streaming capture; ROS2 topic and intrinsics checks
Titan Rover Autonomous Navigation project

Titan Rover — Autonomous Navigation

Group project with the Titan Rover university club — a team of Cal State Fullerton engineering students. Built and contributed to an autonomous rover using ROS, OpenCV, and sensor fusion for real-world terrain navigation and obstacle avoidance.

🤖 ROS 👁️ OpenCV 📡 Sensor Fusion 🗺️ Autonomous Navigation
  • Autonomous terrain navigation with real-time obstacle detection using OpenCV
  • Sensor fusion pipeline integrating camera, IMU, and encoder data
  • ROS-based architecture with custom nodes for perception and motion planning
LoreBook — AI Life Engine

LoreBook — AI Life Engine

A full-stack AI platform that transforms journals, conversations, and memories into a continuously evolving knowledge base of a person's life. LoreBook automatically builds timelines, biographies, relationship intelligence, life arcs, and evidence-backed personal knowledge from unstructured entries.

🧠 Autobiographical Memory 📖 Biography Generation 🔎 Hybrid Retrieval ⚙️ 30+ Analysis Engines
  • Autobiographical Memory System — converts journal entries into structured events, timelines, relationships, and life arcs that persist over time
  • Knowledge Crystallization Engine — detects recurring behavioral patterns and converts them into evidence-backed knowledge claims with confidence scoring and traceable supporting evidence
  • Continuity Intelligence — identifies contradictions, identity drift, abandoned goals, emotional arcs, and recurring behavioral patterns across a user's history
  • Relationship Intelligence System — tracks relationship evolution, influence, interaction patterns, drift, and autobiographical impact across a user's life story
  • Hybrid Retrieval Architecture — combines vector search (pgvector), BM25 keyword search, entity-aware retrieval, temporal weighting, and MMR reranking for context-aware memory retrieval
  • Temporal Reasoning Engine — builds causal chains, life arcs, chronology graphs, and hierarchical timelines from years of journaled experiences
  • Custom orchestration framework: 30+ specialized analysis engines with dependency-aware scheduling, parallel execution, 10–100× caching improvements, and eliminated N+1 bottlenecks
  • Stack: TypeScript · React · Node.js · Supabase/PostgreSQL · pgvector · OpenAI · Stripe · GitHub Actions

CERBERUS — The Guardian Security Suite

An open-source security monitoring and system hardening ecosystem for Windows, Linux, and macOS. Three separate Guardian desktop apps — one for each platform — share one landing page: integrity checks, security posture, network exposure, threat detection, and remediation that stays dry-run until the operator confirms a change.

🖥️ Windows · Linux · macOS 🛡️ Threat Detection 🔒 System Hardening 📖 Open Source
  • Three desktop Guardians — Windows (WinUI 3 / .NET 8), Linux, and macOS — each in its own repository
  • System integrity, security posture, network monitoring, and threat detection on every platform
  • Controlled remediation: dry-run or confirmation-gated until the operator approves a change
  • React landing page that documents what each public Guardian repository actually ships
  • Stack: TypeScript · React · Vite · Tailwind CSS · .NET · Python · Shell

Contact


Open to UAV, robotics, electronics, aerospace, and defense roles. Based in Southern California — open to relocation. US Citizen.

abelxmendoza@gmail.com